Download PDF
Download page Generic Position Integration.
Generic Position Integration
This operating handbook aims to guide users for Generic Position sensor installation and configuration in various applications. This guide is intended for the integration of any external sensor outputting position information (such as SLAM systems, local positioning beacons, or third-party navigation systems).
Data Format
In order to be compatible with our product, the Generic Position aiding must output in sbgECom format. The INS utilizes 3D input position expressed the navigation frame :
- Latitude (in degrees, positive North)
- Longitude (in degrees, positive East)
- Height above ellipsoid (in meters, WGS84)

The covariance matrix must always be provided by the user. If full covariance information is not available, provide a default variance (e.g., 100 m^2 for 10 m standard deviation) and set off-diagonal covariance terms to zero. Note that these values are used at face value within a basic error model, meaning inaccurate variances may lead to navigation issues.
To achieve optimal performance, you can either attempt to tune your own variances or have SBG Systems develop the error model with you.
The SBG_ECOM_LOG_POSITION_1 (62) message is described in firmware documentation.
Mechanical Installation
The position sensor must be rigidly fixed to the vehicle frame to avoid any relative motion with the INS. Additionally, ensure the sensor is placed in a location that maximizes signal reception or visibility, away from environmental obstructions or high-vibration areas that could degrade the external system's accuracy.
The Lever Arm expressed in the vehicle coordinate frame (vehicle reference with X forward, Y to the right, and Z down) from the SBG INS reference point to the position sensor’s measurement point (e.g., antenna phase center or optical center) must be measured with at least 5cm accuracy.
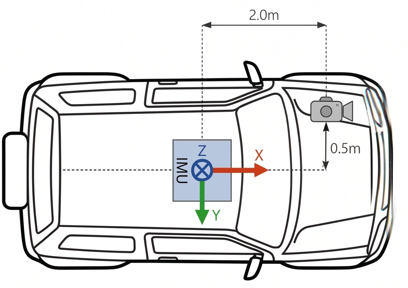
Lever Arm example
Electrical Installation
Data input connection
Regarding the data input, a simple serial connection is generally used, by connecting the Generic Position source serial port to one of the SBG INS available serial ports (eg. PORT B Rx), either in RS-232 or in RS-422.
Synchronization between Generic Position and INS
When used as an input, the TIME_STAMP field of the message may either represent an absolute time or a measurement delay, depending on the status flags. The measurement delay allows the INS to calculate an absolute timestamp based on the reception time, transmission delay, and the specified delay.

The system is highly robust against data latency. The INS can effectively handle and process measurement delays of multiple seconds while maintaining an accurate navigation solution.
Software Configuration
Aiding Assignment
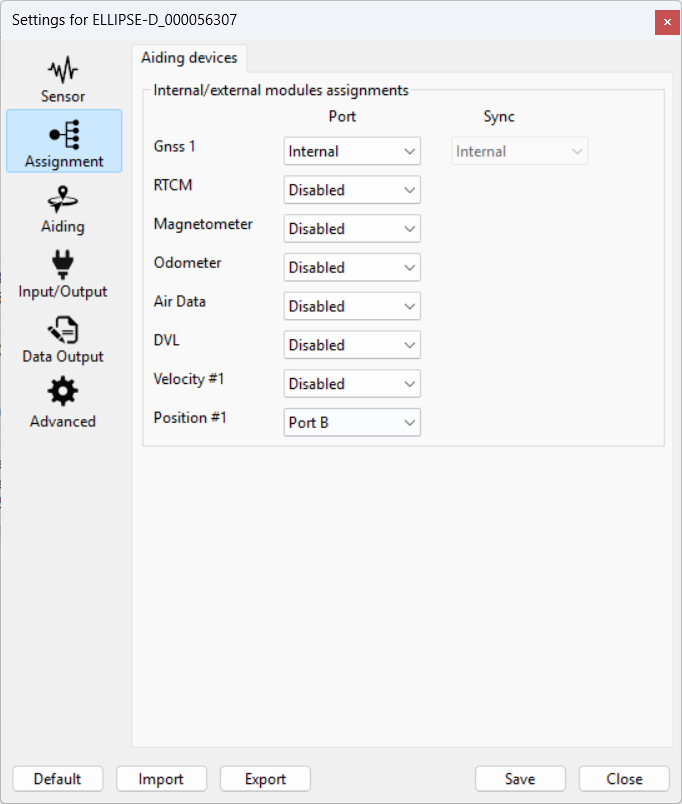
Once a motion profile is selected, you can activate Position #1 by selecting a dedicated source.
Aiding Settings
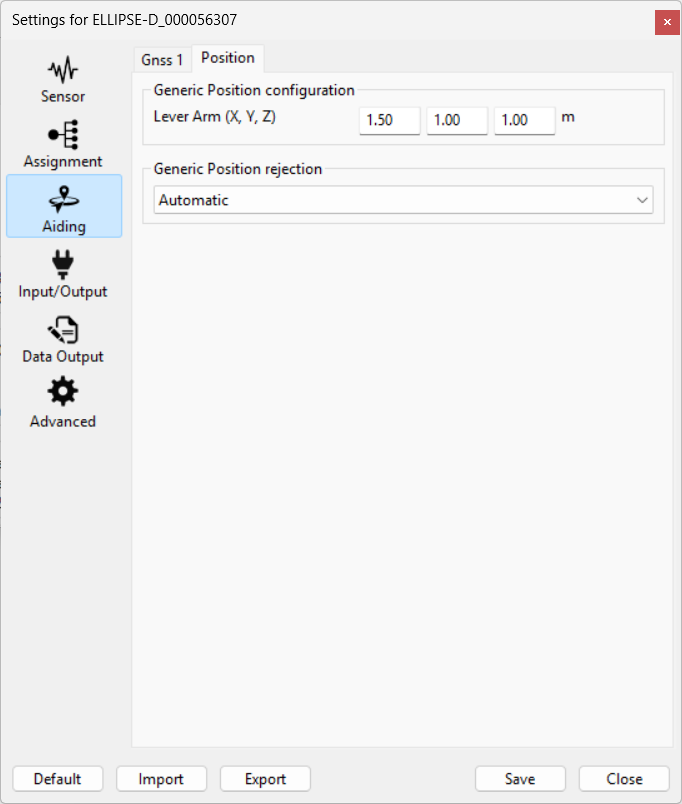
Then you can configure the Lever Arm of the Generic Position sensor (expressed in the vehicle reference frame from the SBG INS reference point to the position sensor’s measurement point).
The Aiding rejection Automatic is advised so the Kalman filter determines the confidence of this parameter by itself.
Input / Output
COM Ports
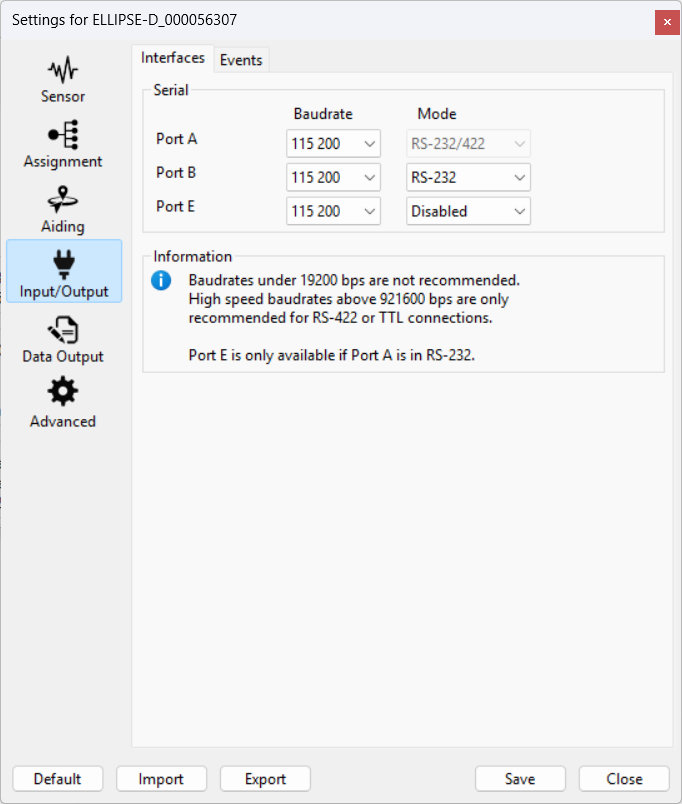
Selected communication port needs to be configured in accordance to your Generic Position Computer.
Data Output
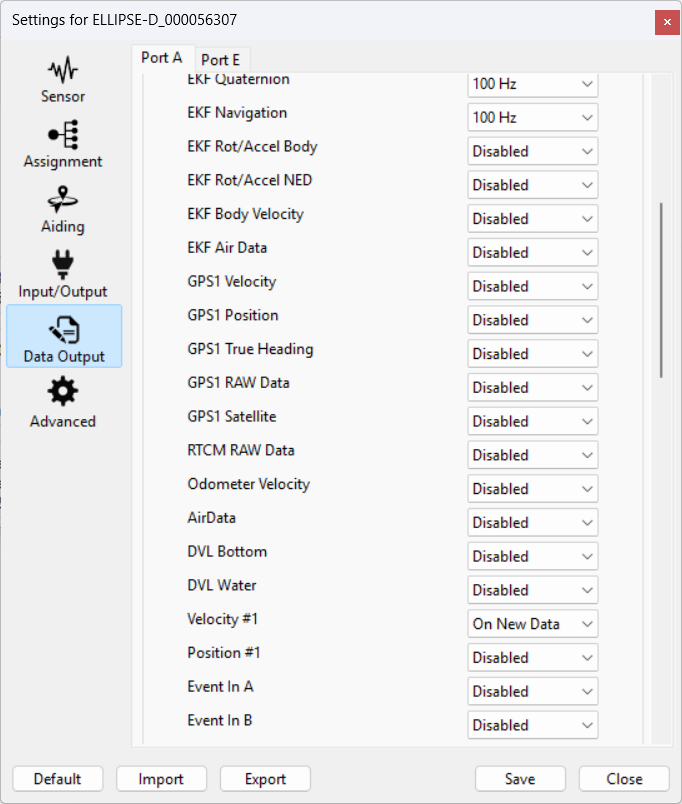
If you also want to output (or log) the generic position message, you can output it (or log it) by activating the dedicated message.
Operation
Data Check
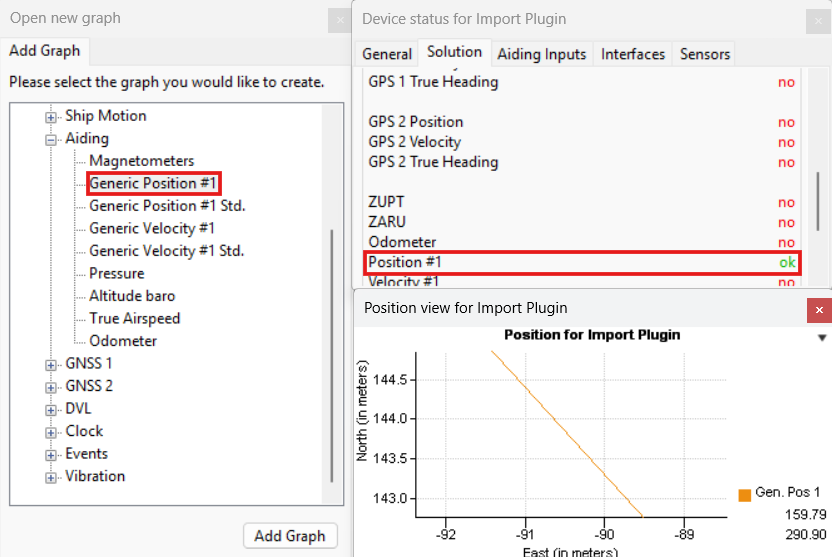
Once configured, it is recommended to check the availability and the order of magnitude of the data received. If Generic Position #1 message is activated on Port A as an output, you can plot it using sbgCenter.
While configuring the Generic Position input may initially seem "plug and play", integrating a new sensor usually requires the development of a dedicated error model. Note that these input values are used at face value within a basic error model, meaning inaccurate covariance matrix may lead to navigation issues.
To achieve optimal performance, you can either attempt to tune your own variances or have SBG Systems develop the error model with you. We highly recommend the second option. By letting us develop the error model, we can ensure the system benefits from better rejection thresholds, optimal standard deviation dilution, and overall improved robustness.
Because we do not expect most integrations to work perfectly out of the box without this tuning, we recommend the following workflow:
- Plug and check: Connect your sensor, configure the output, and verify data availability within the software.
- Acquire data: Record a representative dataset of your vehicle in standard operating conditions.
- Contact SBG Systems: Reach out to our technical support team with your acquired data so we can help you assess the quality the fusion.