Download PDF
Download page 6.3.2880-stable.
6.3.2880-stable
This release brings several new features, performance improvements, and bug fixes to the 6.x firmware series. At its core, it introduces initial support for our newly launched INS, Stellar-40. It also extends support for subsea navigation by introducing new aiding sources and includes significant improvements to PTP capabilities, performance and reliability.
The update is compatible with, and recommended for, all Stellar, Ekinox, Apogee, Navsight, and Quanta users to ensure the best possible performance and user experience.
The main highlights and the detailed changelog are provided below.
You can download and install this firmware release free of charge using the link below:
Important highlights
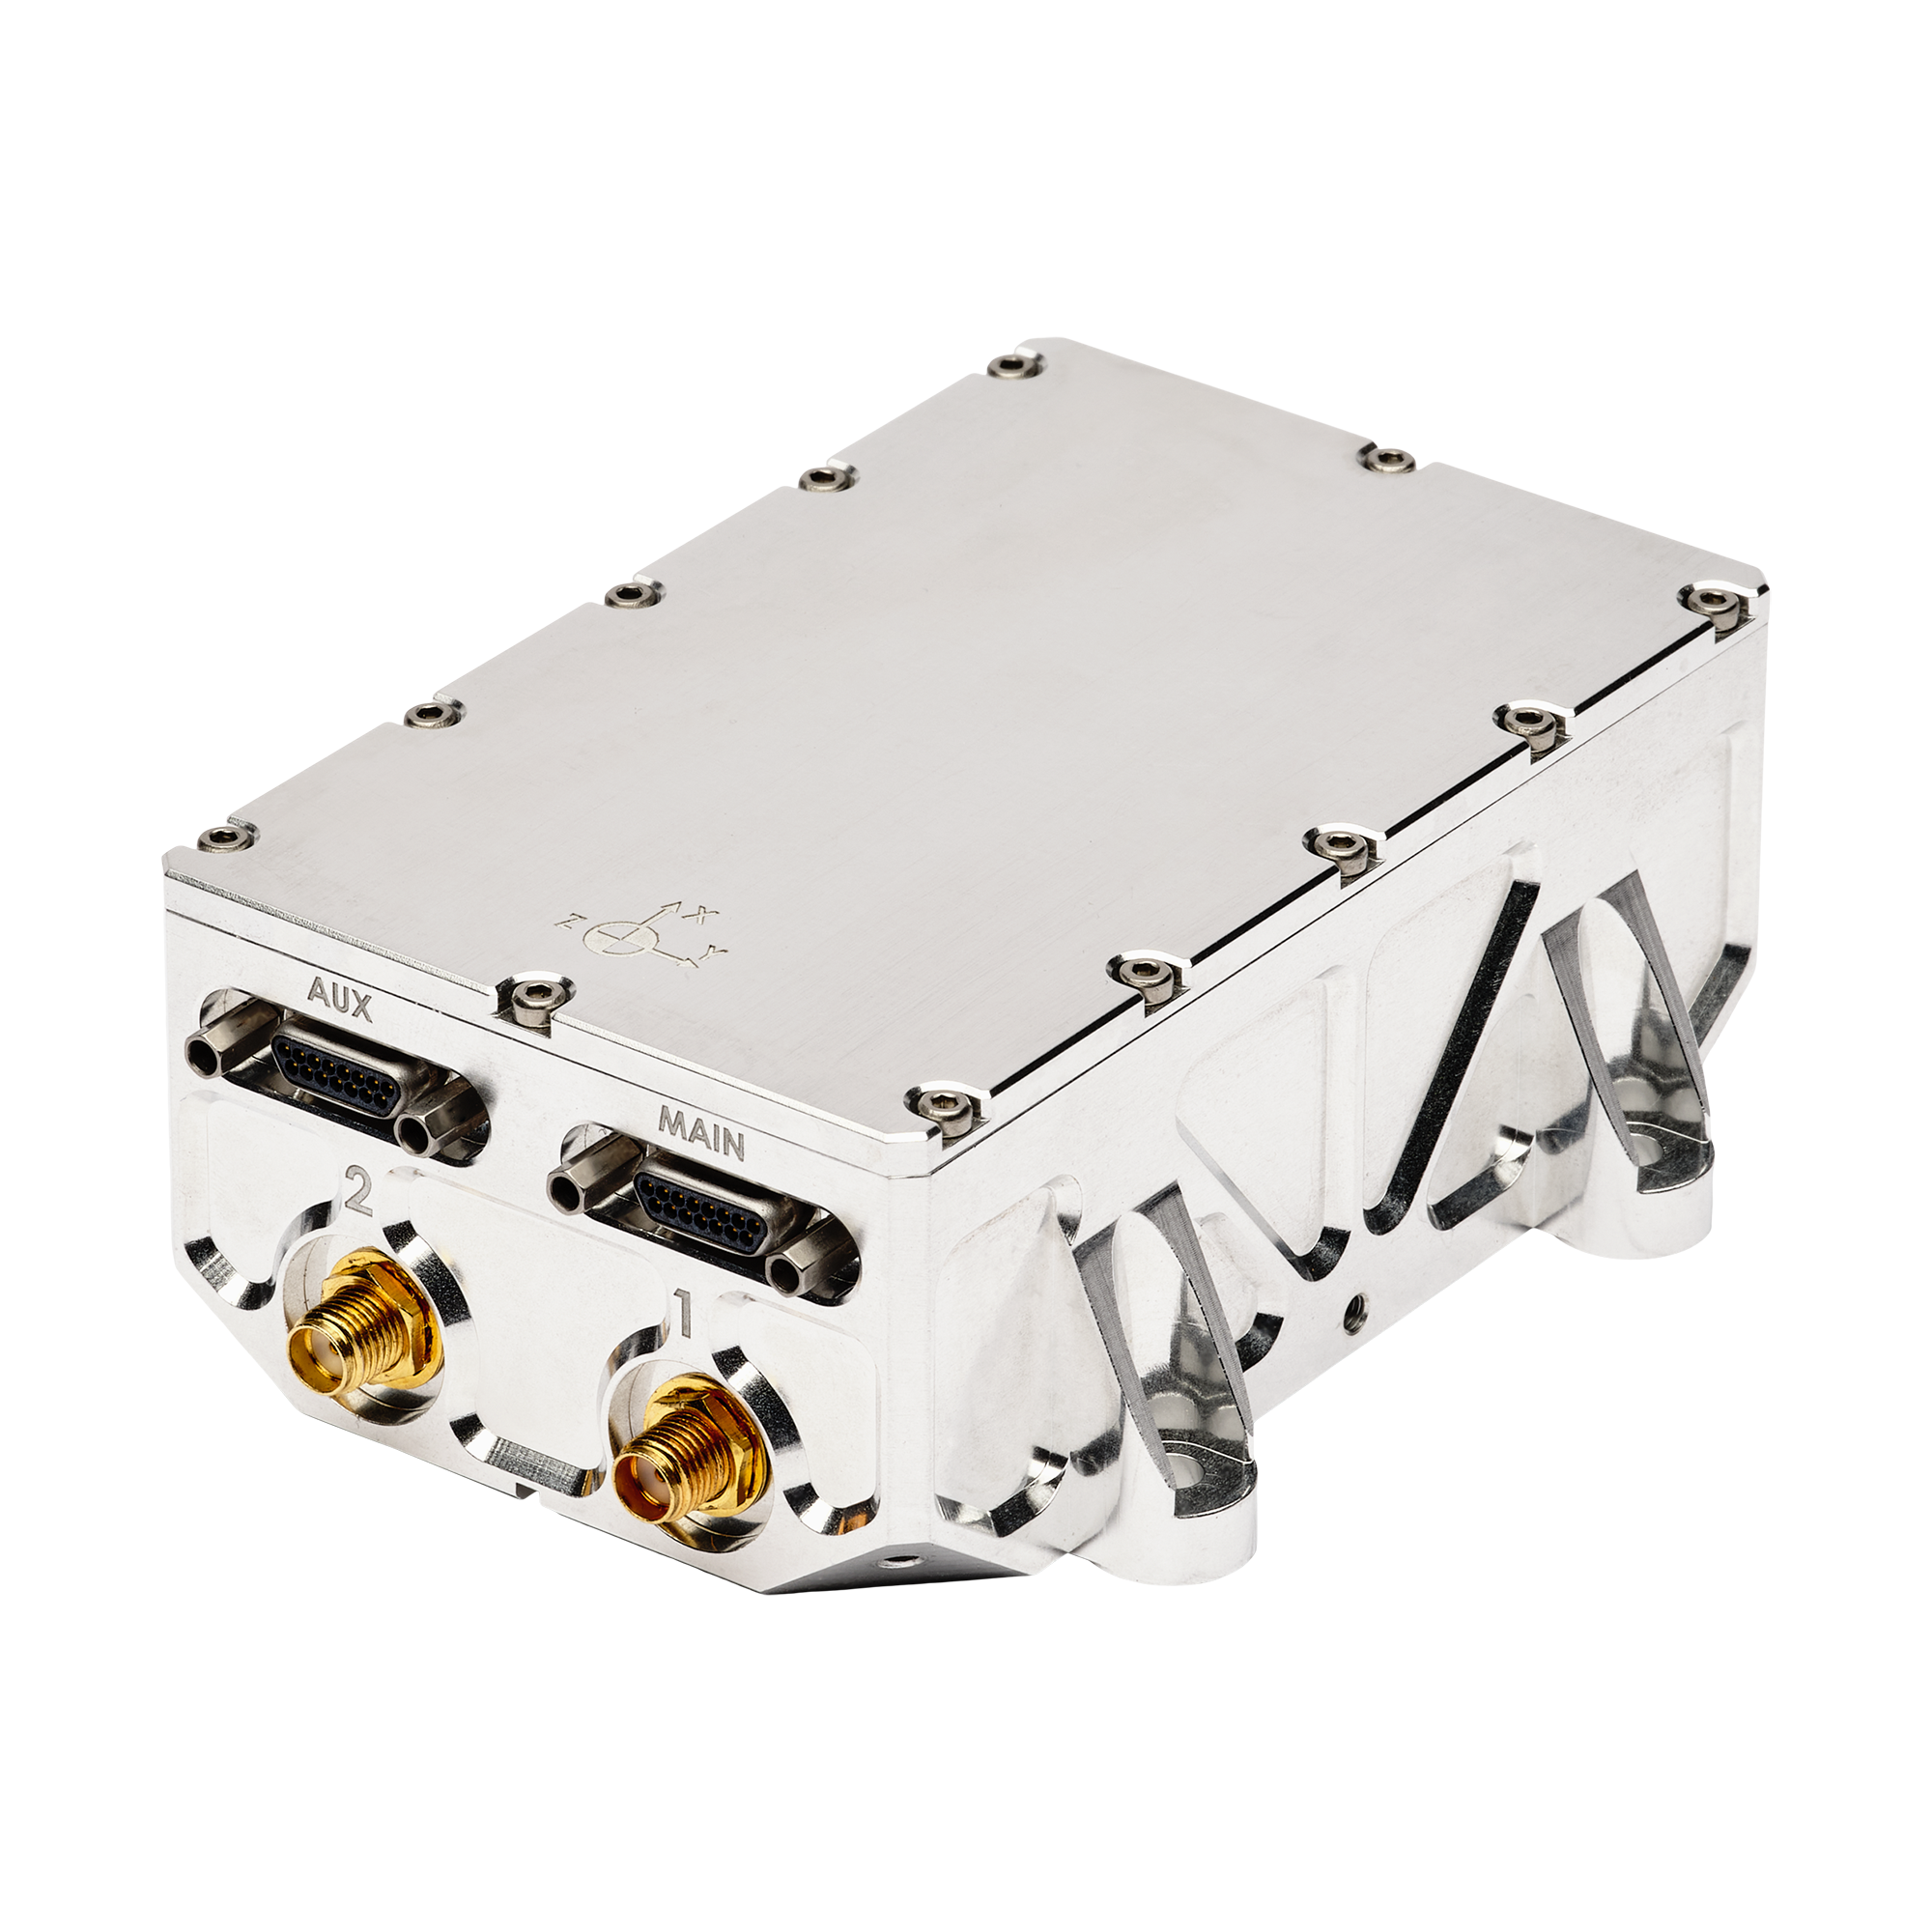
Support of our new INS STELLAR-40
The 6.3.2880-stable is the first release with complete support of Stellar-40, our new resilient INS.
For more details please refer to:
- For the presentation of Stellar-40: https://www.sbg-systems.com/ins/stellar-40/
- For the technical specifications of Stellar-40: Stellar-40 Documentation
Stellar-40 uses the same Firmware and APIs as other SBG products, so all developments performed using an Ekinox, an Apogee or a Quanta can directly be used with Stellar-40.
Manual alignment before mission start
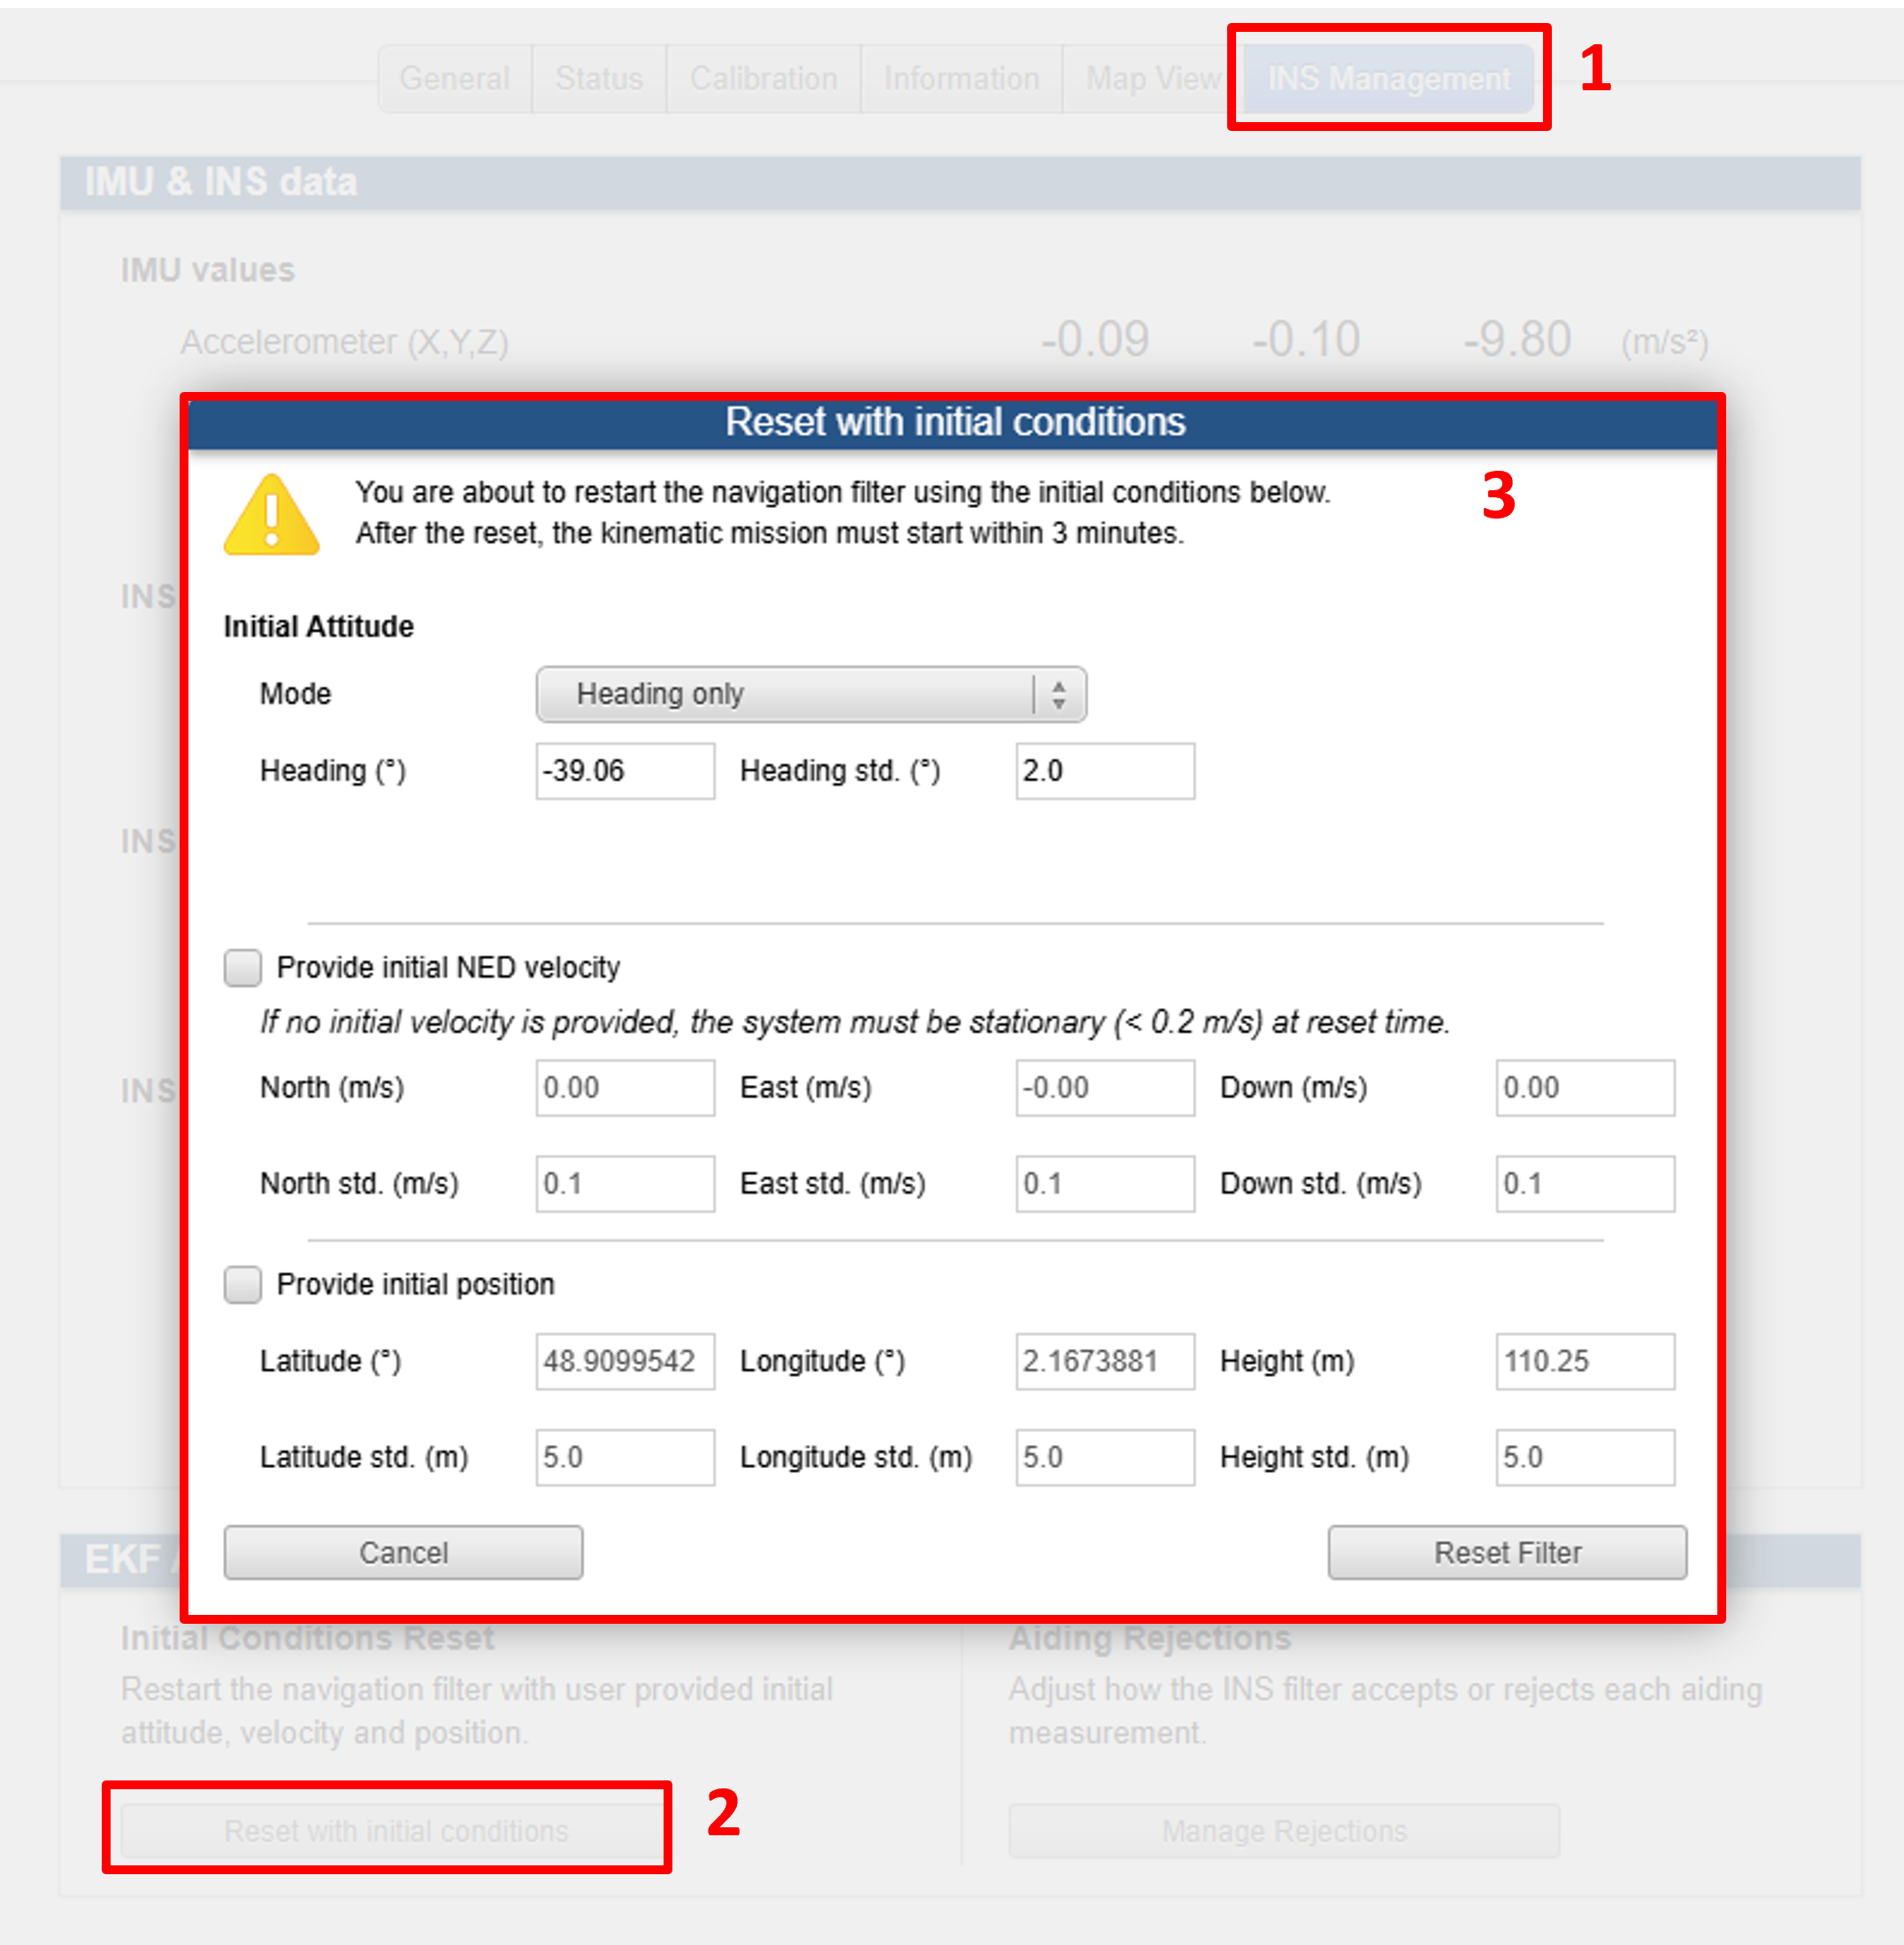
A significant number of use-cases for our INS involves operation where the full initialization is needed before the start of the mission but where dual antenna GNSS is not accessible and magnetometer is not usable.
To support these operations, we have added a new feature allowing manual initialization of the INS before the mission start. These can be used through:
- The sbgInsRestAPI: Configuration API (sbgInsRestApi)
- The embedded web interface.
This advanced feature requires careful configuration. Contact us for more details.
Subsea navigation: Depth sensor and USBL support
In order to improve SBG Systems INS subsea navigation capabilities in the future, initial support for USBL and depth is provided.
This support includes configuring a USBL sensor as a new aiding source and introduction of new dedicated sbgECom messages (see https://developer.sbg-systems.com/sbgECom/5.8/binary_messages.html#SBG_ECOM_LOG_USBL and https://developer.sbg-systems.com/sbgECom/5.8/binary_messages.html#SBG_ECOM_LOG_DEPTH for details)
At the moment, those messages are only generated and recorded for Qinertia replay, and not used in real time within sbgEKF algorithm. Contact us for more details or support of other vendors.
New PTP features
PTP is a sub-microsecond precise time synchronization over ethernet protocol than can replace legacy "PPS based" mechanism and is proposed within SBG Systems INS since firmware version 4.0.168-stable. With this release, in addition to performance improvement, we extend the coverage of possible operation modes with a full PTP slave support, where the SBG Systems INS will steer it's clock from another grandmaster available on the network. The coverage also includes support of the following native PTP management messages:
- LOG_DELAY_REQ_INTERVAL
- DELAY_MECHANISM
- PORT_STATE
- CLOCK_DESCRIPTION
- DEFAULT_DATA_SET
- CURRENT_DATA_SET
- PARENT_DATA_SET
- PORT_DATA_SET
- TIME_PROPERTIES_DATA_SET
Release notes 6.3.2880-stable
New features
- EKIFW-3083 - Add support for STELLAR products
- EKIFW-3158 - Web: Add a rejections management interface
- EKIFW-3136 - Web: Add initial attitude/velocity/position filter reset interface
- EKIFW-3134 - WebUI: Add local param settings
- EKIFW-3121 - Add sbgECan EKF Air Data message
- EKIFW-3100 - Add support for Water Linked JSON and Serial DVL protocols
- EKIFW-3092 - Add support for Nortek DVL 500 Compact Depth
- EKIFW-3056 - Add a depth aiding support
- EKIFW-2971 - Add USBL aiding support
- EKIFW-2910 - Add support for Nortek Nucleus Depth Sensor
- EKIFW-3099 - Add new CAN message with GNSS number of reboots and up time info
- EKIFW-3031 - Add settings to configure OSNMA public keys
- EKIFW-3027 - PTP: Add support for PTP (IEEE 1588) Management Messages
- EKIFW-3025 - PTP: Add support for slave mode
- EKIFW-2962 - Add support of Ublox X20P
Improvements
- EKIFW-3325 - Update the sensor fusion algorithm to version 6.2.666-stable
- EKIFW-3189 - Update IMU firmware to 3.4.443-stable
- EKIFW-2974 - Restart Septentrio GNSS when spoofing is detected
Bug fixes
- EKIFW-3337 - NTP: Fix replies when unsynchronized
- EKIFW-3299 - Fixed EKF reset when velocity is not provided (default velocity to 0)
- EKIFW-3289 - IMU: Fix rare PULSE-40 v1 gyroscope initialization failure
- EKIFW-3288 - IMU: Fix CBIT reporting false gyroscope errors on some PULSE40v1 units during high-rate rotations
- EKIFW-3285 - Fix handling of rejection modes on EKF filter reset
- EKIFW-3226 - Web: Fix multiple rejection application failure
- EKIFW-3203 - Fix GGA source (GNSS instead of INS) for differential correction
- EKIFW-3178 - Clock: Improve reported estimated clock error in free running mode
- EKIFW-3172 - Fix factory reset action that also clear installed licences
- EKIFW-3170 - Web: Fix odometer lever arms description
- EKIFW-3157 - Fix Indyn message heading range
- EKIFW-3152 - Fix air data unsupported model error after update from firmware 5.5 to firmware 6.2
- EKIFW-3150 - Fix NMEA VTG and RMC mode indicators that are not compatible with standard
- EKIFW-3144 - Fix NMEA GGA PPP quality indicator for Septentrio receivers

Upgrading from 4.0 and older
If you are upgrading from a firmware 4.0 or older, you should first install the failsafe firmware before you can install the correct firmware type package.
Please refer to the dedicated Update Procedure for a step by step guide.