Download PDF
Download page Main Interface.
Main Interface
This brief document describes the various tabs and content of the main interface window.
You have the choice between 5 tabs in the selector:
Each tab will display several frames with various data content. Some frames will depend on the sensor - Motion Profile selected in Configuration, it will be thoroughly described in each tab pages.
- General Tab - Shows Vehicle motion, navigation and attitude EKF solutions with a system summary.
- Status Tab - Shows detailed status of IMU, GNSS input, Solution, Aiding inputs, interfaces & clock/time.
- Calibration Tab - Allows a complete calibration of GNSS antennas lever arm (Main & secondary antenna). Please refer to the our dedicated How-To for a complete guide on the Lever Arms Calibration Procedure.
- Information Tab - Shows device's information, its firmware's version, the current network settings, and the internal datalogger status.
- Map View Tab - Show a live Map to monitor system position and heading.
- INS Management Tab- Shows in real-time the IMU data & INS computed attitude, velocity, position.
Each tab will display several frames with various data content. Some frames will depend on the Motion Profile selected in Configuration, it will be described in each page.
On the top right corner, three buttons are available:
- Configure Menu - Access to the INS configuration menu.
- Role Login Menu- Access to the user's login/role menu.
- Support Center Website- Access the SBG Support web page.
All frames are displaying excerpts from various sbgECom messages, the complete list of sbgECom messages and format can be found in the sbgECom documentation or in the Firmware Reference Manual..
General Tab
The following frames are displayed in General tab:
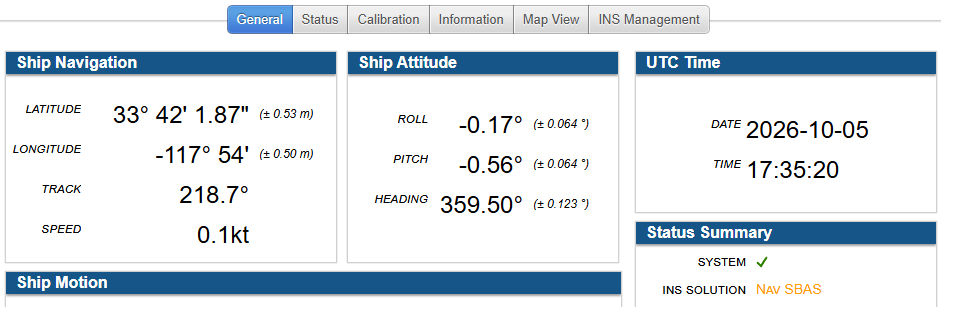
- Position / Ship Navigation (Marine profiles) - This shows EKF navigation position [SBG_ECOM_LOG_EKF_NAV]
- Orientation / Ship Attitude (Marine profiles) - This shows EKF Euler solution [SBG_ECOM_LOG_EKF_EULER]
- Status Summary - This shows a quick view status summary of INS/IMU solution type, GNSS status, Time status and protocol, clock & datalogger status & UTC time (& Heave Status for Marine profiles).
- Velocity (Land/Air profiles) - This shows EKF Nav Velocities [SBG_ECOM_LOG_EKF_NAV]
- Ship Motion (Marine profiles) - This shows EKF Ship Motion [SBG_ECOM_LOG_SHIP_MOTION] solution at 2 monitoring points.

Profile differences in display
The screen captures below were made on a static unit on top of a building and show differences between Marine profile and Land Air profile.
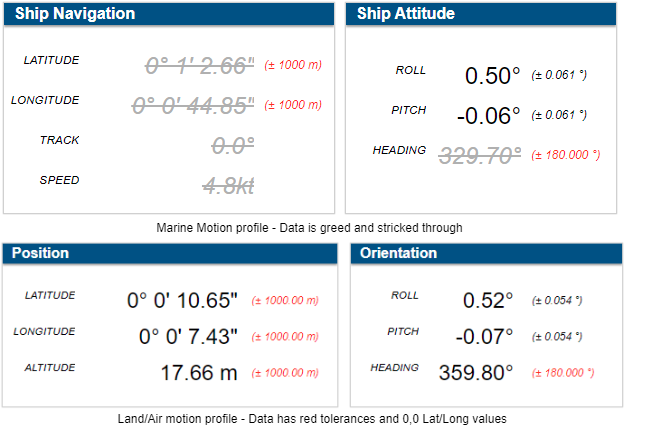

EKF mode
Above we see that only Pitch & Roll have a solution, if you see the data greyed out or with anomalous tolerances it means that EKF is not in Navigation mode, but in Vertical Gyro mode. More details on SBG EKF modes of Operation.
Status Tab
The status tab displays the health of the system, grouped by category.
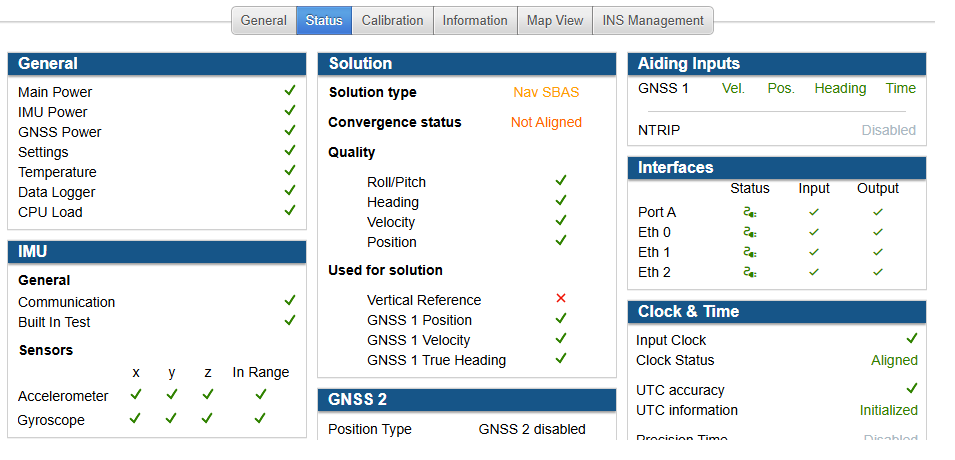
It contains the following Frames:
- General - Display the general status [SBG_ECOM_LOG_STATUS/GENERAL_STATUS].
- IMU - Display the IMU status [SBG_ECOM_LOG_IMU_DATA/IMU_STATUS].
- GNSS1 - Display the GNSS1 status [SBG_ECOM_LOG_GPS1_POS/GPS_POS_STATUS, STATUS_EXT and SBG_ECOM_LOG_GPS1_HDT/GPS_HDT_STATUS].
- Solution - Display the EKF Solution status [SBG_ECOM_LOG_EKF_EULER/SOLUTION_STATUS
- Aiding inputs - Display the Aiding status [SBG_ECOM_LOG_STATUS/AIDING_STATUS].
- Interfaces - Display the interfaces status [SBG_ECOM_LOG_STATUS/COM_STATUS and COM_STATUS_2].
- Clock & Time - Display the Clock & Time status [SBG_ECOM_LOG_UTC_TIME/CLOCK_STATUS and UTC_STATUS].
- Ship Motion (Marine profiles) - Display the Ship motion status [SBG_ECOM_LOG_SHIP_MOTION/HEAVE_STATUS]
GNSS2 will display (like GNSS1) the status of the input of an optional external GNSS receiver.
Calibration Tab
The Calibration tab allows you to perform a mechanical Lever Arms Calibration
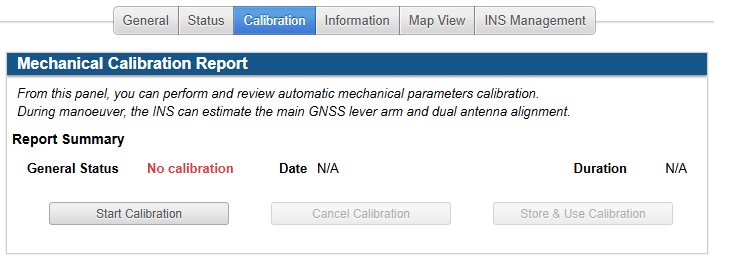
- Calibration Tab - For the complete guide on the Lever Arms Calibration Procedure.
Information Tab
The Information tab display important device's information
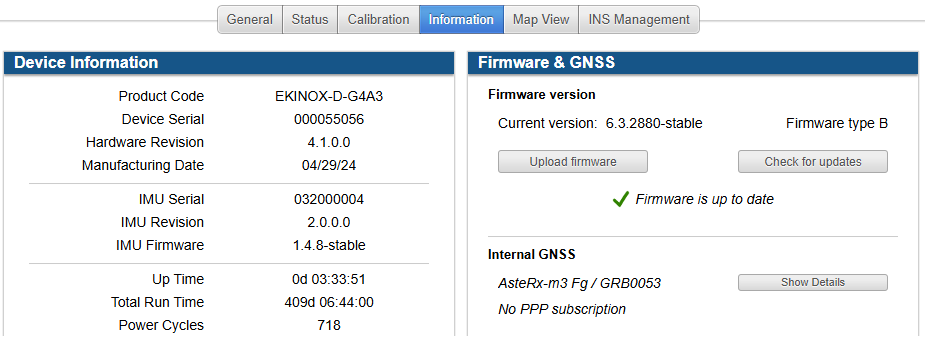
- Serial number, IMU firmware version, hardware version.
- Firmware version with Firmware Update button and Internal GNSS information button.
- Current network settings.
- Internal datalogger status and a few buttons.
We suggest taking a screen capture of your information tab so you can access valuable information to give to support even if the unit is powered off.
Map View Tab
The Map View tab shows a Live Map, a convenient way to monitor system position and heading. (since firmware 5-5-3789-stable release)
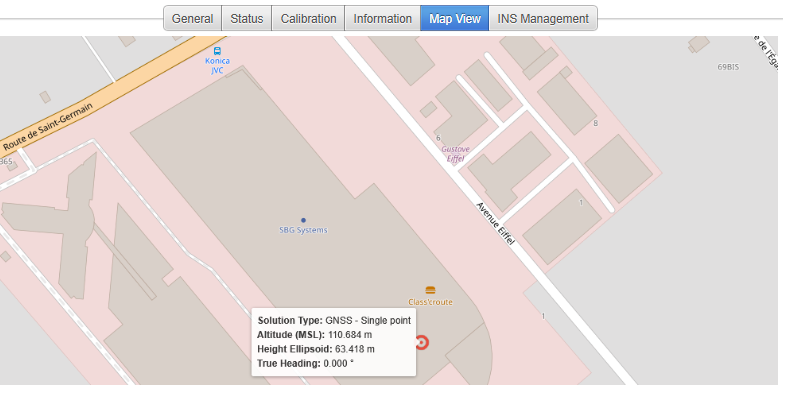
The map even works offline, displaying a low-resolution view when no internet is available at the browser side.
INS Management Tab
INS Management tab is a measurements tab, it displays the real-time IMU sensors & INS data attitude, velocity, position.
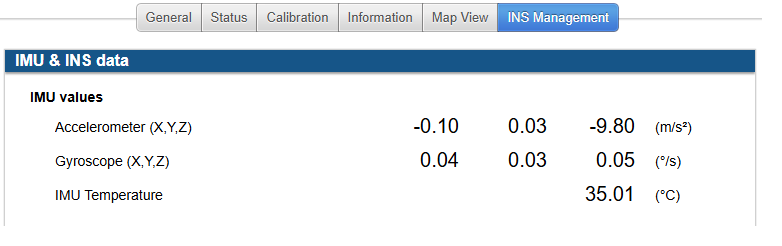
- IMU values from [SBG_ECOM_LOG_IMU_SHORT].
- INS attitude from [SBG_ECOM_LOG_EKF_EULER].
- INS Position from [SBG_ECOM_LOG_EKF_NAV].
- INS Velocity from [SBG_ECOM_LOG_EKF_VEL].
Since the release of firmware 6.3.2880-stable, there are also at the bottom two buttons for EKF Actions These actions enable you to modify specific behaviors of the INS without resetting the navigation filter or rebooting the unit. They are explicit commands to use in order to stop using a specific aiding source in the sensor fusion algorithm while maintaining data output continuity.

Use case of actions
It is important to note that these actions are not settings and cannot be saved as part of the INS configuration ; they are only applicable during the current power cycle of the unit and will be lost upon reboot.
They are perfectly suited for temporary rejections of an aiding sensor when you know it should not be used: for example a system using magnetometer and starting next to a large metal mass (a marine vessel, a catapult...) can reject the magnetometer on startup and activate it afterwards to avoid improper heading initialization.
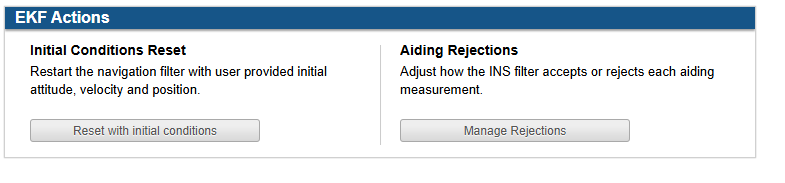
- Initial Conditions Reset : Restart the navigation filter with user provided initial attitude, velocity and position.
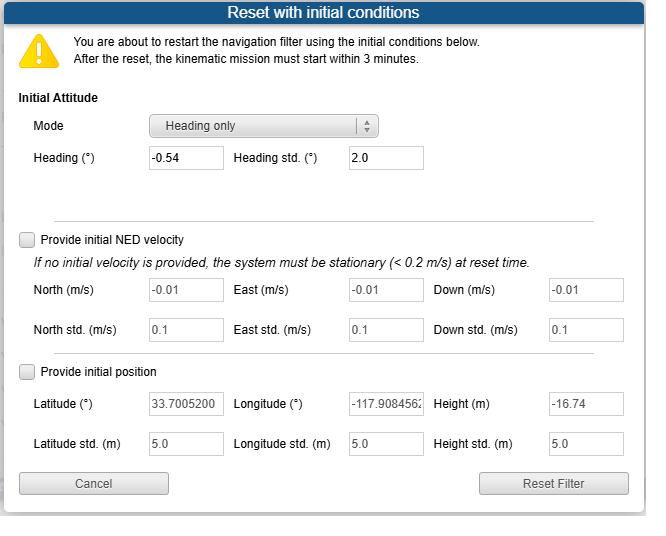
The different options in the Initial Attitude mode drop-down-box are:
- Heading only (you need to provide the Heading and it's accuracy 1σ)
- Full Attitude (roll, pitch, yaw and their accuracies 1σ)
- Full Attitude (quaternions and their accuracies 1σ)
Optionally, you can also provide an initial NED velocity and/or provide an initial position.
This can also be managed via the sbgInsRestApi, chapter Operating the device - INS - Reset INS with initial conditions
- Aiding Rejections:
Adjust how the INS filter accepts or rejects each aiding measurement ('on the fly' means without rebooting the EKF).
Note : this is temporarily as it is not saved in settings.
More thorough details on the page Use Aiding Rejection Modes .